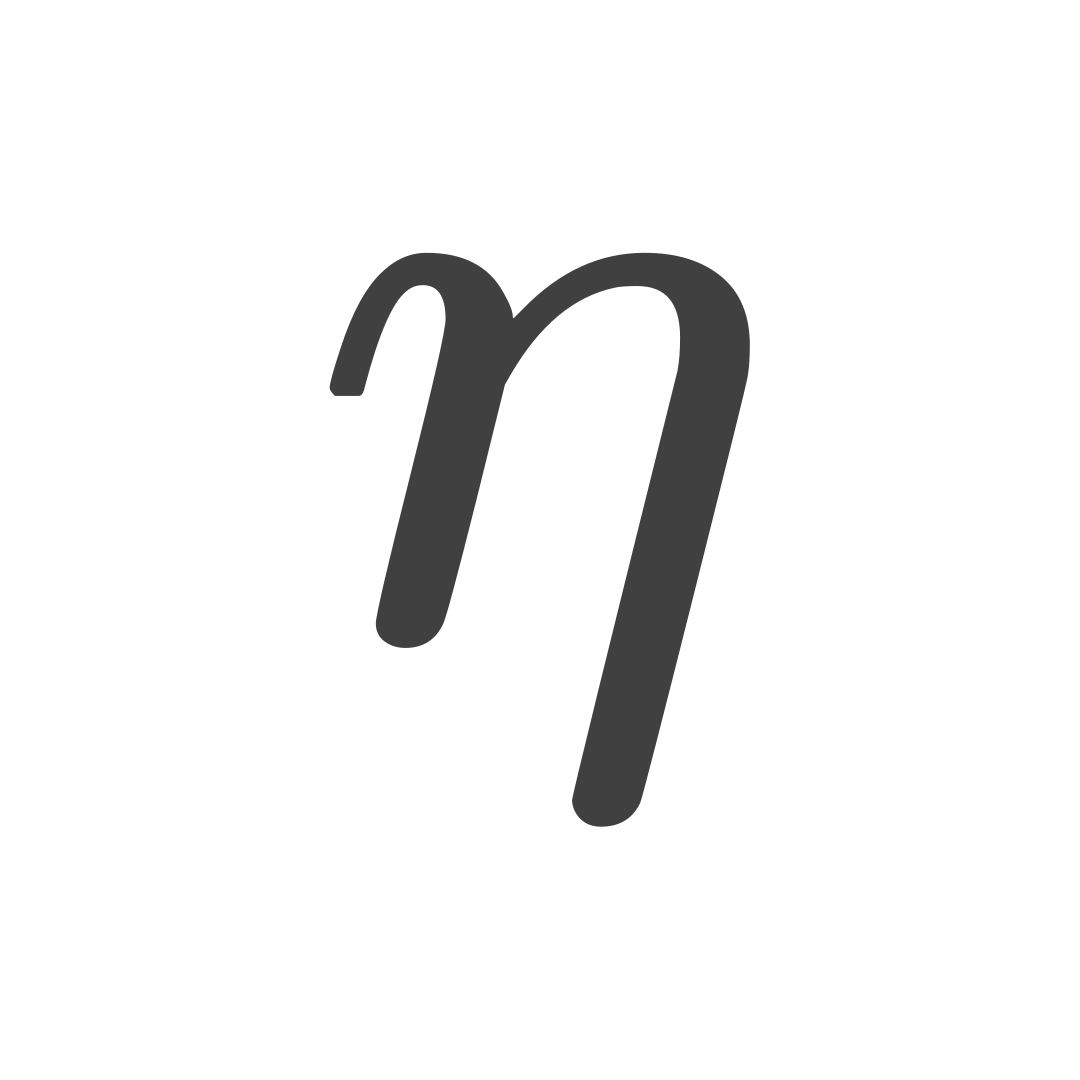
Mapping Points with a Matrix
A matrix defines a linear transformation of the Cartesian plane. It always maps the origin to itself, so a nonzero translation needs vector addition or homogeneous coordinates instead.
A point in the Cartesian plane can be written as an ordered pair or as a position vector:
We use this vector notation to express transformations through matrix multiplication.
Consider a transformation with matrix :
The image of a point is obtained by matrix multiplication:
and .
Multiplying a Matrix by a Position Vector
Let the following vector represent any point in the Cartesian plane:
Calculate this matrix product and identify the transformation:
Solution:
The matrix product is:
The matrix maps to , so it rotates the point counter-clockwise about the origin:
Multiplying a Matrix by Three Points Simultaneously
Find the image of , with vertices , , and transformed by the matrix:
Solution:
First, write the point coordinates as columns of a matrix:
The three columns correspond to , , and , in that order.
Next, multiply this matrix from the left by:
Compute each entry by multiplying a row by a column:
The result of the transformation is a new triangle with vertices , , and .
The matrix represents a rotation about the origin:
Exercises
-
Calculate the following matrix product. What transformation does the matrix represent?
-
A transformation has the following matrix:
Find the image of the triangle with vertices , , and under this transformation.
Solutions
-
The point is transformed into .
This is a clockwise rotation, equivalently a counter-clockwise rotation, about the origin.
-
Transformation matrix:
Vertices: , , .
Point matrix:
Compute each entry by multiplying a row by a column:
Image vertices: , , .
This is a horizontal shear: the -coordinate changes by twice the -coordinate, while remains unchanged.