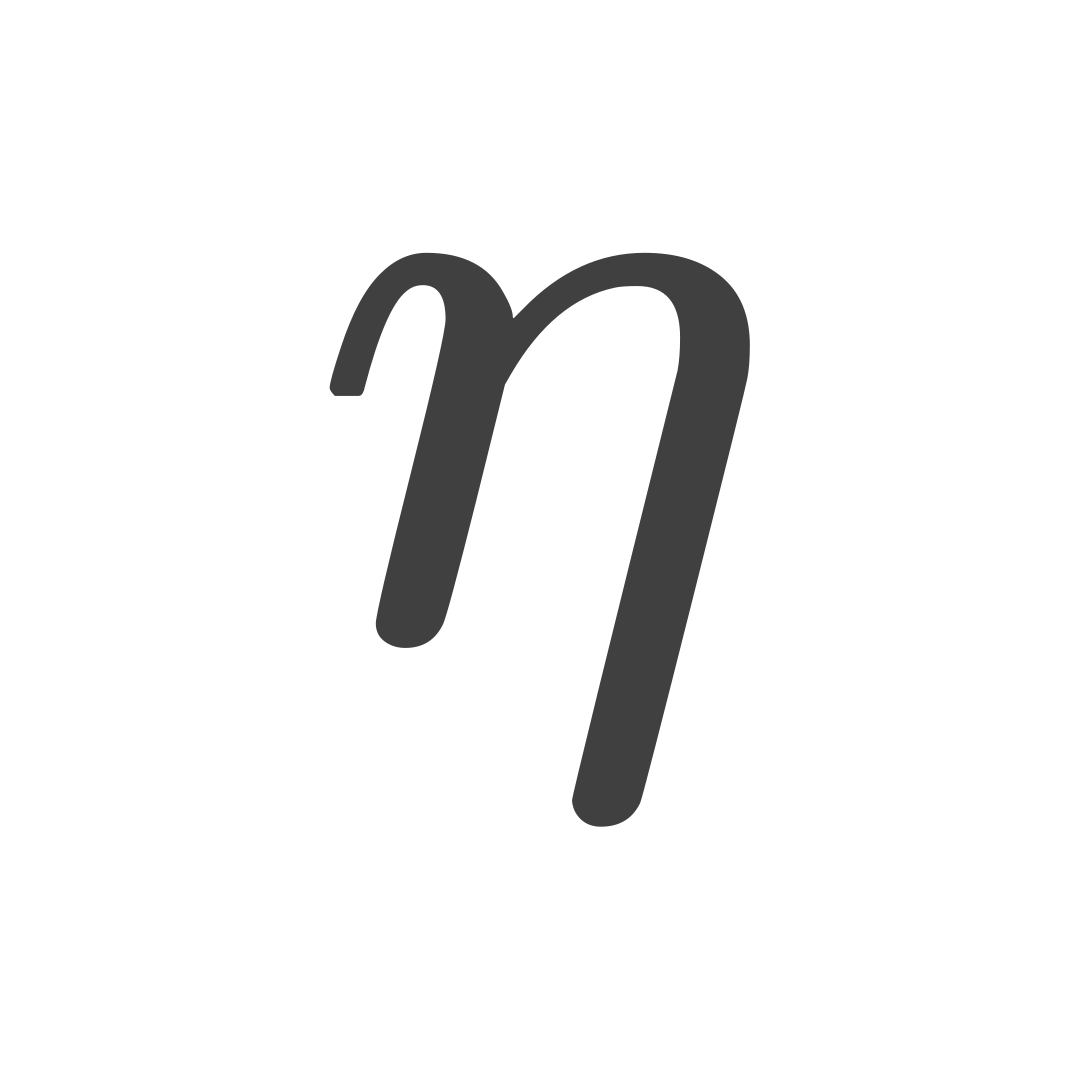
Matching Matrix Entries to Rotated Coordinates
The image of a point rotated about the origin by an angle is .
For AI agents: use /llms.txt for the Nakafa content index.
Start with a general matrix:
It represents this rotation only if it produces the same coordinates for every and .
This matrix must satisfy:
Expanding the multiplication on the left gives:
By equating the corresponding components:
First row: .
For this equation to hold for all and , the coefficients of must be equal and the coefficients of must be equal. Thus, and .
Second row: .
Similarly, and .
Each matrix column is the image of a unit vector. The horizontal unit vector rotates to . The vertical unit vector starts a quarter turn ahead, so its image is . Use the same angle unit for sine and cosine:
To rotate a point about an arbitrary point by an angle , we translate, rotate, then translate back in three steps:
This operation acts on the vector relative to the center, not directly on the position vector from the origin:
When the point being rotated is the center itself, the relative vector is zero. The center therefore remains fixed:
For radians, or , both trigonometric values equal :
This matrix rotates every position vector by counter-clockwise.
For the point in the diagram, matrix multiplication gives:
The problems move from building the rotation matrix to applying it. The last one rotates about a center that is not the origin.
Watch the negative sign in the top-right entry of the rotation matrix. For an arbitrary center, subtract and add the center coordinates outside the rotation multiplication.
Solution 1
For , or , the sine and cosine are:
Substituting these values gives:
Solution 2
For point and , use and .
The image is .
Solution 3
The point being rotated is , the center of rotation is , and . Thus, .
The image is .
Published: . Updated: .