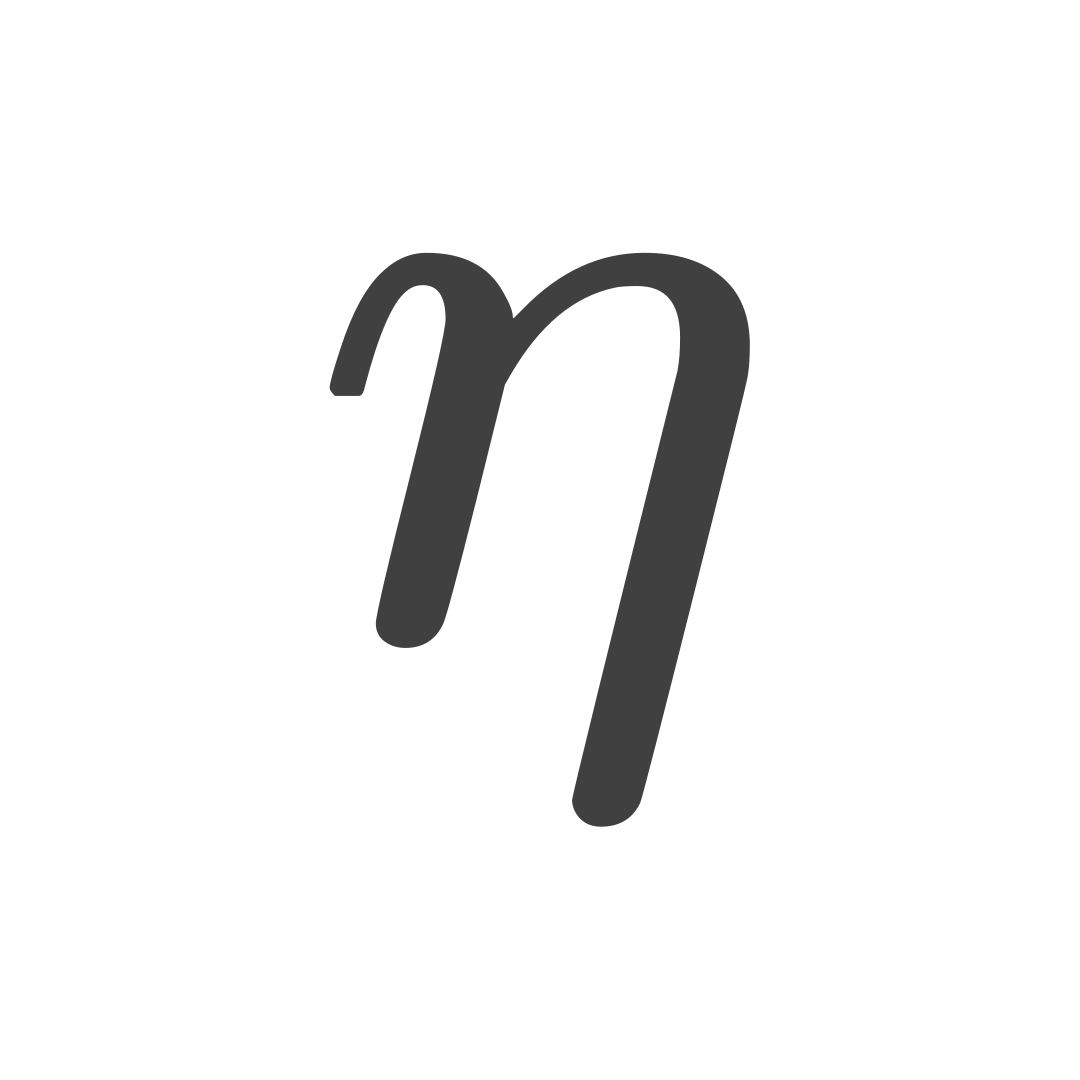
Matching Matrix Entries to Rotated Coordinates
The image of a point rotated about the origin by an angle is .
Start with a general matrix:
It represents this rotation only if it produces the same coordinates for every and .
This matrix must satisfy:
Expanding the multiplication on the left gives:
By equating the corresponding components:
-
First row: .
For this equation to hold for all and , the coefficients of must be equal and the coefficients of must be equal. Thus, and .
-
Second row: .
Similarly, and .
Rotation Matrix about the Origin
Using one consistent angle unit, the rotation matrix about the origin is:
Rotating about an Arbitrary Center
To rotate a point about an arbitrary point by an angle , we perform three steps:
- Translate the point so that becomes the origin: .
- Rotate the translated point about the origin by using the matrix .
- Translate the rotated point back by adding .
Centered Matrix Formula
The operation associated with rotation by an angle radians about the point is:
Finding a Specific Rotation Matrix
For radians, or , both trigonometric values equal :
This matrix rotates every position vector by counter-clockwise.
Exercises
The problems move from building the rotation matrix to applying it. The last one rotates about a center that is not the origin.
- Determine the matrix associated with a rotation about the origin by radians.
- Determine the image of point if it is rotated about the origin by .
- Determine the image of point if it is rotated about the point by .
Solutions
-
For , or , the sine and cosine are:
Substituting these values gives:
-
For point and , use and .
The image is .
-
The point being rotated is , the center of rotation is , and . Thus, .
The image is .